Introduction
Parallel operation of transformers enables flexible power distribution and provides reserve capacity during outages. Transformers with tap-changers require coordinated voltage control so that different open-circuit voltages do not cause unwanted circulating reactive currents. Digital regulators such as the freely programmable REGSys® voltage regulation system perform this task with high control quality.
In brief: During parallel operation, the regulators must consider both the busbar voltage and the loading of the participating transformers. REGSys® provides master-slave, master-follower, ΔIsinϕ, ΔIsinϕ(S) and Δcosϕ control methods for this purpose.
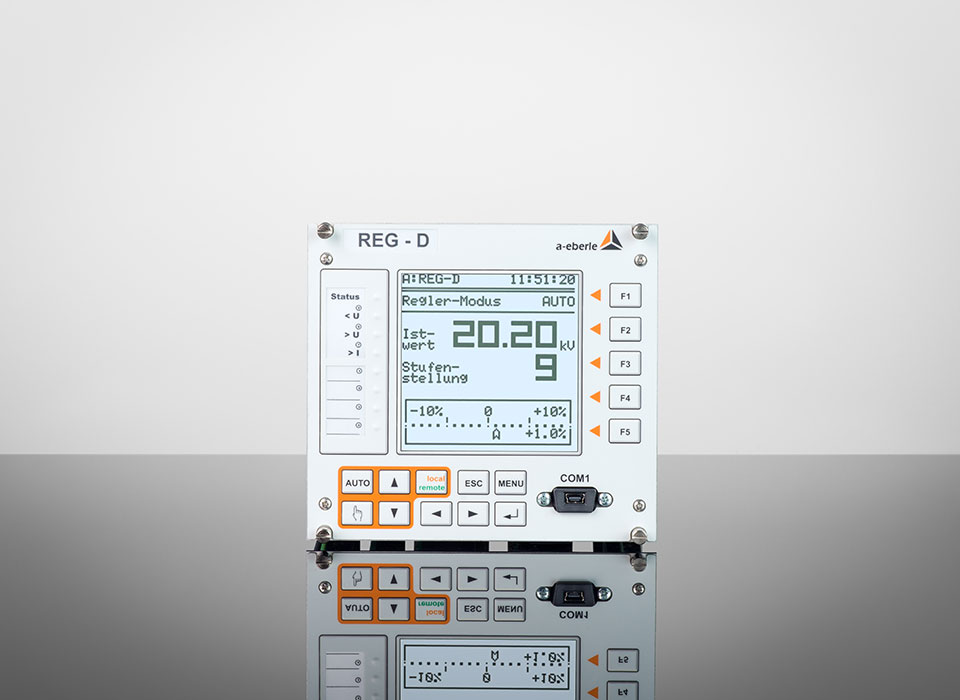
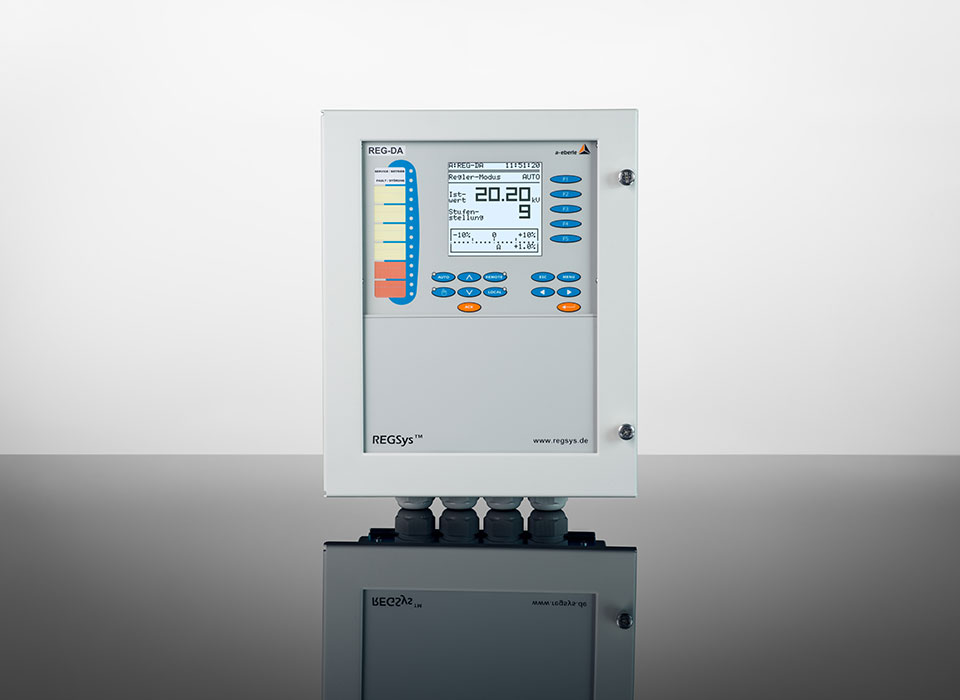
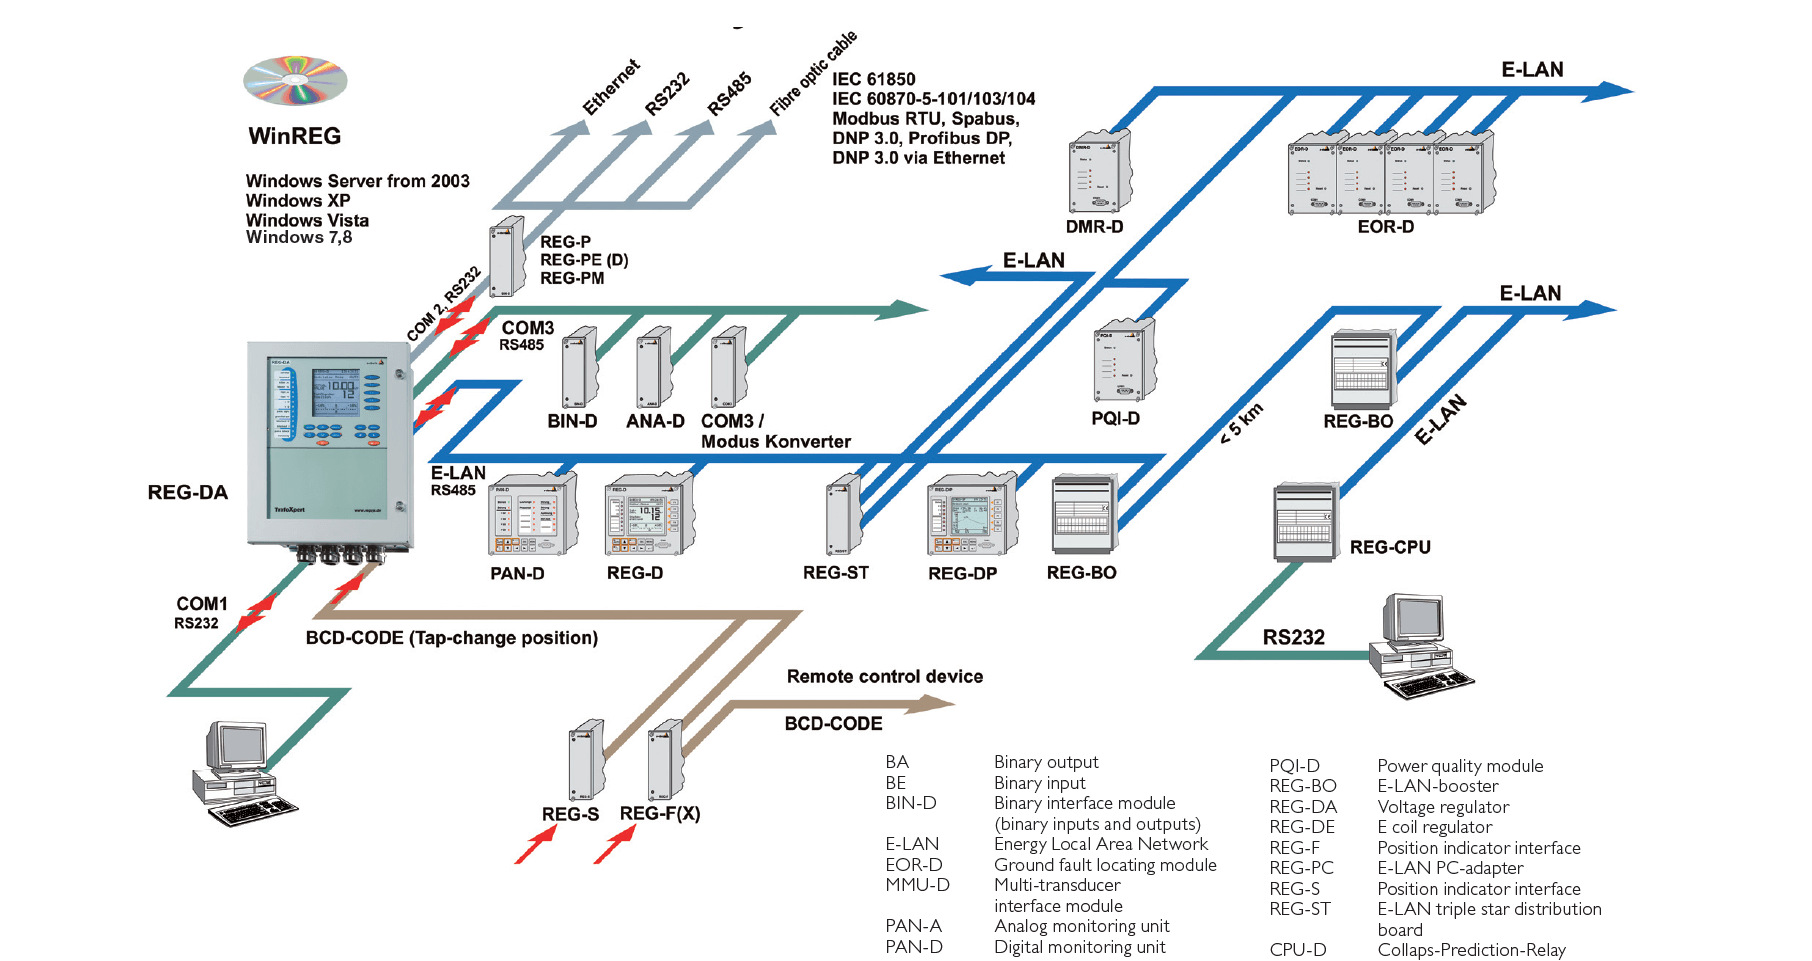
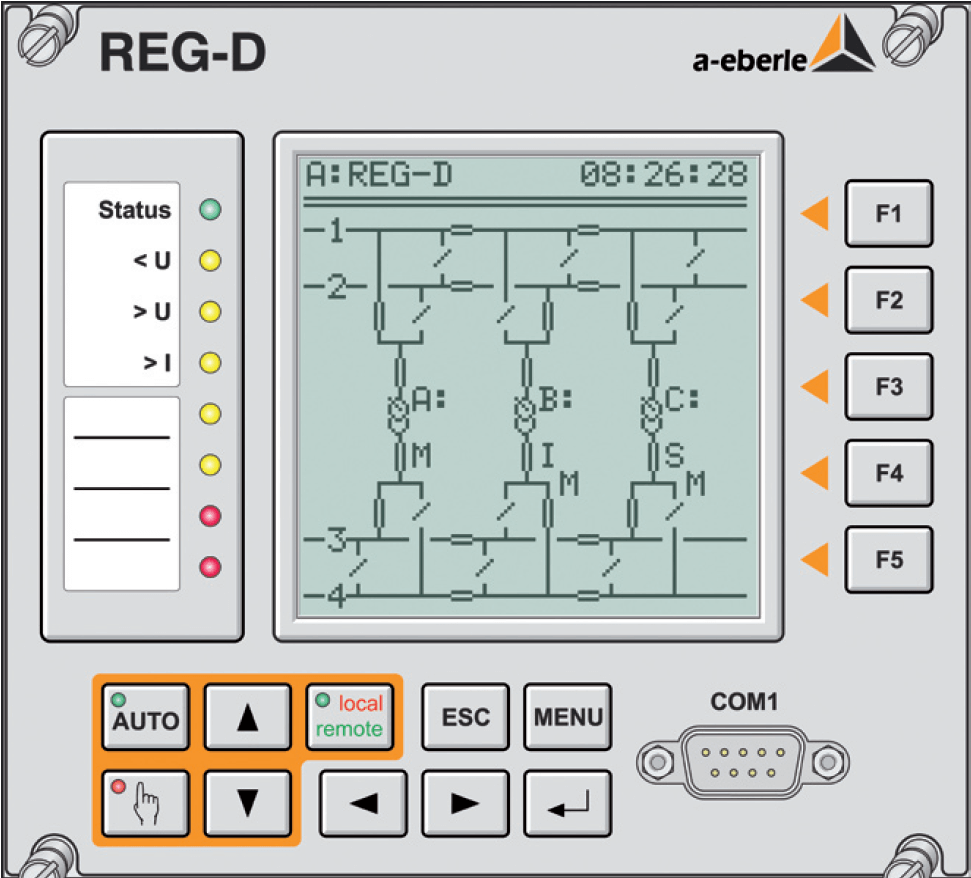
The core of the REGSys® voltage regulation system (Figure 1) is the REG-D® voltage regulator. In addition to voltage control, it performs measurement, recording and statistical functions. Users configure the regulator either from its keypad or through the menu-guided WinREG software on a PC. Communication interfaces are particularly important for parallel operation. The dual E-LAN regulator bus (RS485 interface) enables data exchange between up to 255 regulators. This removes the need for costly additional measuring equipment or separate parallel control units.
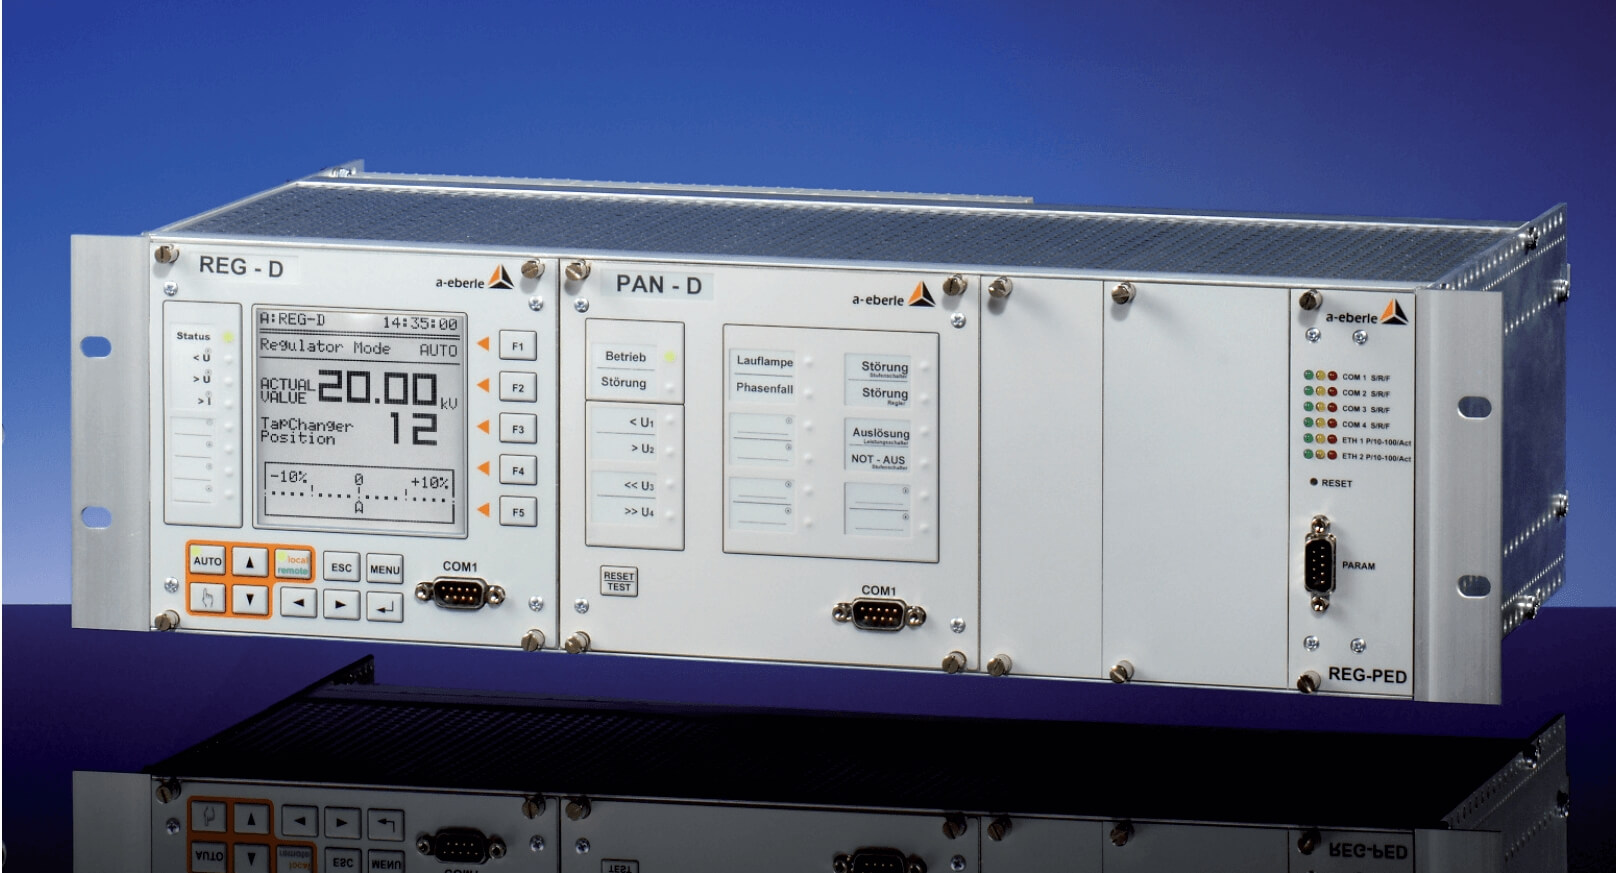
The COM 1, COM 2 (RS232) and COM 3 (RS485) serial interfaces connect PCs, modems, supplementary interface modules and higher-level SCADA systems. Analogue and binary inputs and outputs support a wide range of measurement and control functions around the transformer. They can provide tap position feedback or implement a setpoint changeover, for example. Figure 2 shows how the system can be expanded to include Petersen coil control and earth-fault location.
Key Points for Parallel Operation of Transformers
- Different open-circuit voltages can cause substantial circulating reactive currents because transformer impedances are low.
- Master-slave and master-follower control use matching tap positions and are particularly suitable for identical transformers.
- ΔIsinϕ and ΔIsinϕ(S) determine the circulating reactive current from measured reactive currents; ΔIsinϕ(S) also considers rated power.
- Δcosϕ operates without an E-LAN connection and serves as an emergency programme in the REG-D® if bus communication fails.
Parallel Operation of Transformers With Tap-Changers and REGSys®
Controlling a single transformer is straightforward, but the conditions become more complex during parallel operation. Several transformers can share the required power and provide reserve capacity during outages. Where several feeders require supply, operators can connect the transformers in parallel to different busbars according to demand. This allows the system to cover power peaks flexibly.
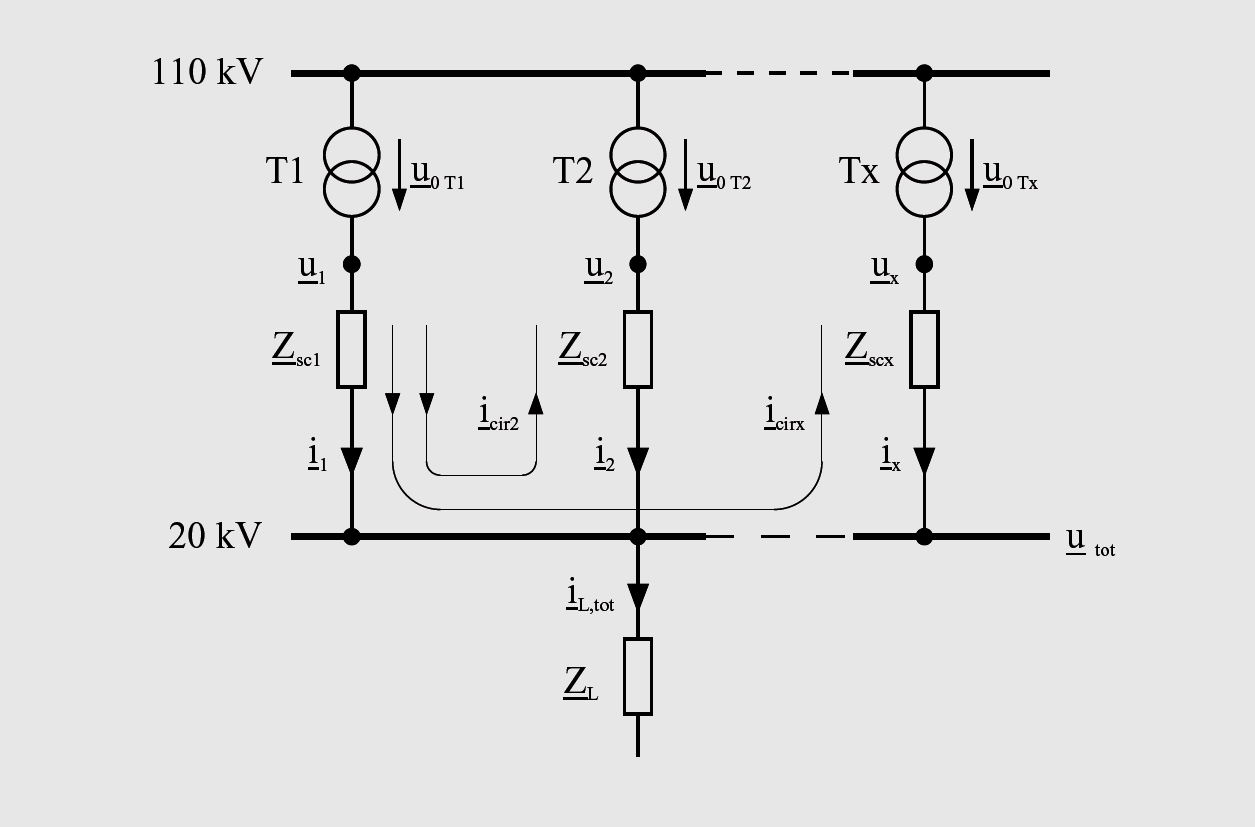
Figure 3 shows the parallel connection of n transformers as an equivalent circuit and explains why parallel operation requires special precautions. If the driving voltage u1 is higher than u2 to ux, the circulating currents icir2 to icirx flow. Their magnitude depends on the short-circuit impedances Zsc1 to Zscx and on the differences between the open-circuit voltages u1 – u2 to u1 – ux. Transformer impedances are normally very low. Transformers with mismatched tap settings can therefore carry substantial circulating currents, which may overload them or at least produce an unfavourable load distribution. The following equations show these relationships:
iT1 = i1 + icir2 + … + icirx (1)
iT2 = i2 – icir2 (2)
iTx = ix – icirx (3)
Why Do Circulating Reactive Currents Complicate Control?
The example shows that all circulating currents place an additional load on transformer T1, while each circulating current relieves the corresponding other transformer. Transformer impedances are strongly inductive and their active component is negligible. These currents are therefore also called circulating reactive currents.
Voltage control also loses sensitivity because a change in the individual open-circuit voltages u1 to ux affects the total busbar voltage only partly. If the impedances Zsc1 to Zscx are equal and the control changes one transformer by Δux, the following applies:
u’tot = utot + Δux / n (4)
Equation (4) shows that with three transformers connected in parallel (n = 3) and equal impedances, a voltage change at one transformer affects the busbar voltage by only one third. This makes voltage control considerably more difficult. If transformers at higher tap positions compensate for transformers at lower tap positions, the busbar voltage may be correct while circulating currents still flow. Parallel control therefore requires additional measured variables.
Control Methods for Parallel Operation
REG-D® Control Methods and Their Applications
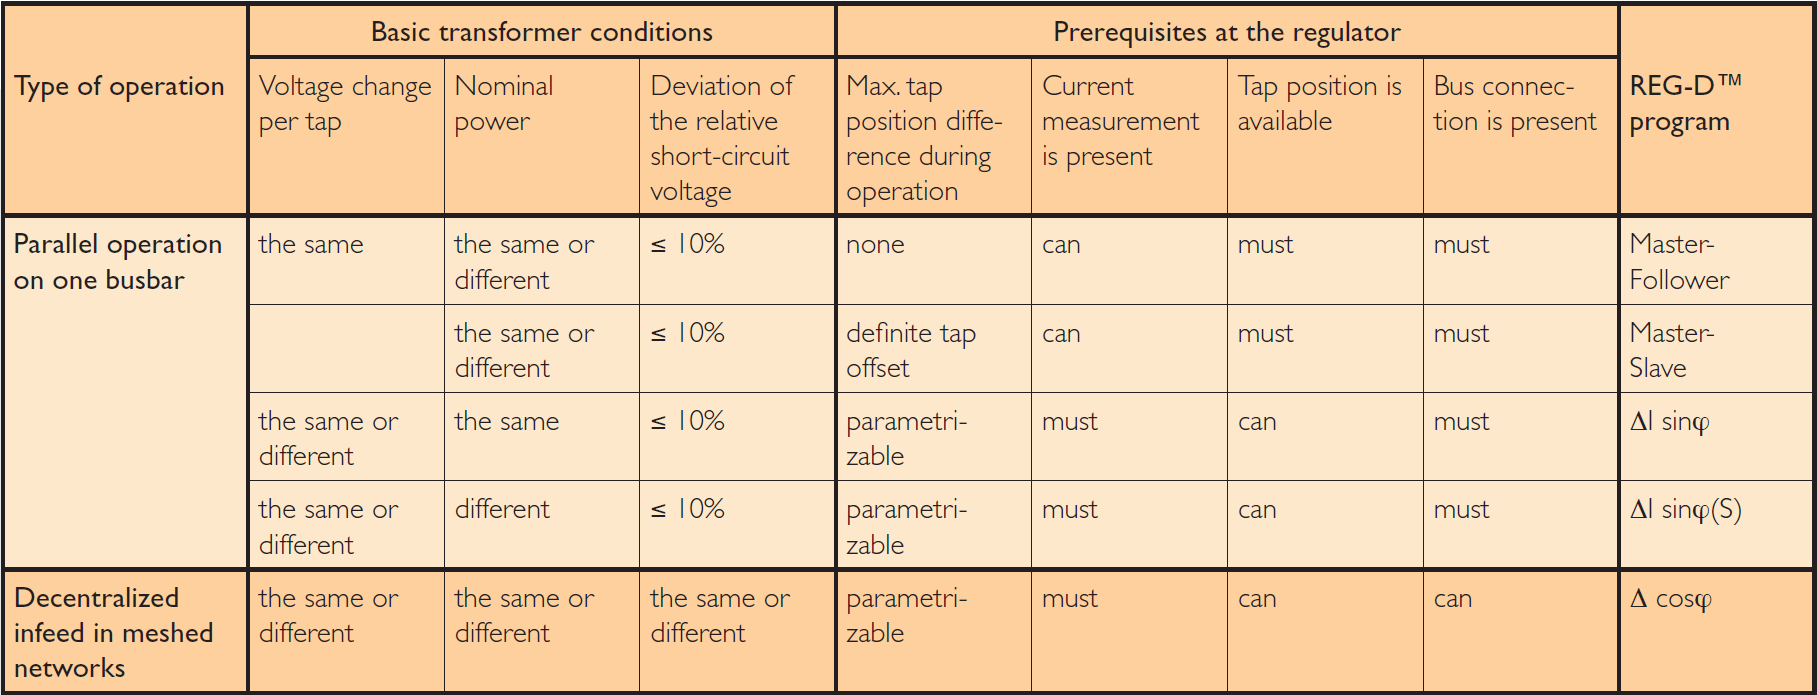
REG-D® uses two fundamentally different groups of voltage control methods. Master-slave and master-follower control the voltage and tap positions. ΔIsinϕ, ΔIsinϕ(S) and Δcosϕ also consider the circulating reactive current. Table 1 and Figure 8 compare the applications and requirements of these methods.
| Method | Principle and application |
|---|---|
| Master-slave | One master issues tap commands and the slaves follow. The method is particularly suitable for identical transformers. |
| Master-follower | The follower reads the master tap position via E-LAN and independently corrects an initial tap difference. |
| ΔIsinϕ | The method determines circulating reactive current from the measured reactive currents and distributes the target reactive current equally. |
| ΔIsinϕ(S) | The calculation also considers rated power, allowing the reactive current to be distributed in proportion to transformer ratings. |
| Δcosϕ | The method requires no bus connection and suits widely meshed networks as well as emergency operation after an E-LAN failure. |
Master-Slave and Master-Follower Methods
These methods bring the transformers to matching tap positions. With master-slave control, one regulator leads while the other regulators follow its tap commands. With master-follower control, the follower reads the master tap position via E-LAN and independently moves to the same position. A deliberate tap difference present at the start remains unchanged with master-slave control. The master-follower method corrects this difference.
Both methods are particularly suitable for identical transformers. They can also operate transformers with different rated powers. In that case, equal tap positions must produce equal transformation ratios and therefore equal open-circuit voltages. For good control results, the relative short-circuit voltages of the transformers must not differ by more than 10%.
Circulating Reactive Current Methods
These methods determine the circulating reactive current from the currents at the transformer infeeds. They then minimise it by changing the transformer tap positions selectively.
ΔIsinϕ Method
A simple measurement of the transformer reactive current is not sufficient to determine the circulating reactive current. An inductive load can also cause reactive current (see ix in Figure 3). With two transformers in parallel, the circulating reactive current equals half the difference between the two measured reactive currents. The calculation eliminates the load-related component. With several transformers, the method adds all reactive currents and divides the total by the number of transformers. The result is the reactive current that each transformer would need to supply to cover the load's reactive power demand. According to Figure 3:
iL,tot = iT1 + iT2 + … + iTx (5)
Substituting equations (1) to (3) into equation (5) gives:
iL,tot = i1 + icir2 + … + icirx + i2 - icir2 + ix - icirx (6)
All circulating currents cancel out in equation (6). This gives:
iL,tot = i1 + i2 + … + ix (7)
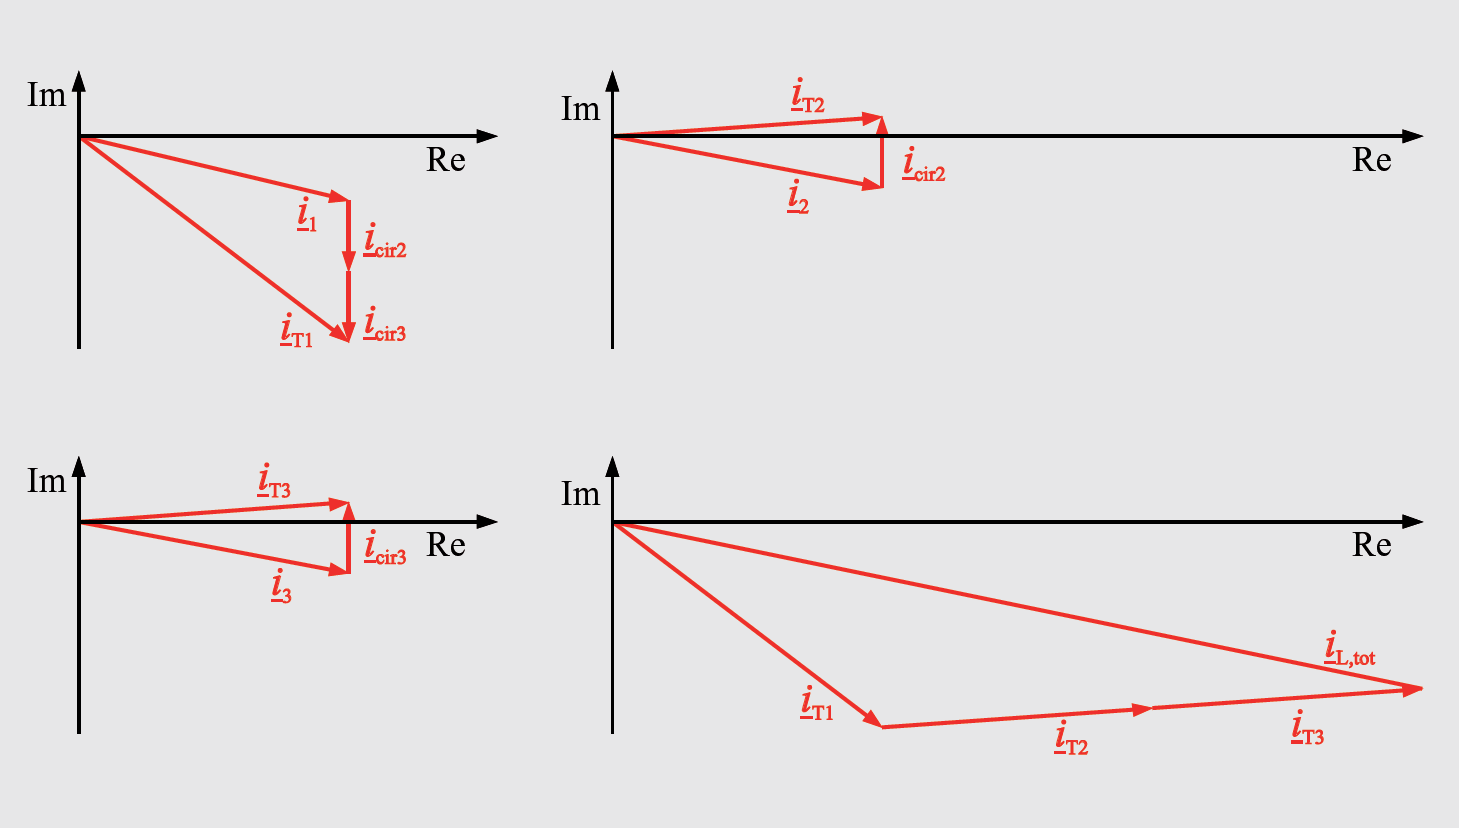
The relationships in equations (5), (6) and (7) also apply to the reactive components IQx. Adding the transformer reactive currents gives the total load reactive current (see Figure 4).
Calculating the Target Reactive Current
To determine the target reactive current per transformer, the method divides the total reactive current by the number n of transformers. Each transformer would need to supply this target value to cover the reactive power demand of the loads. The circulating reactive current icirQx of a transformer is therefore the difference between the measured reactive current and the target reactive current:
icirQx = iQx - (iQ,tot · 1/n) (8)

icirQx: circulating reactive current of transformer No. x
iQx: reactive current component of transformer No. x
iQ,tot: reactive component of the total current across all transformers
ΔIsinϕ(S) Method
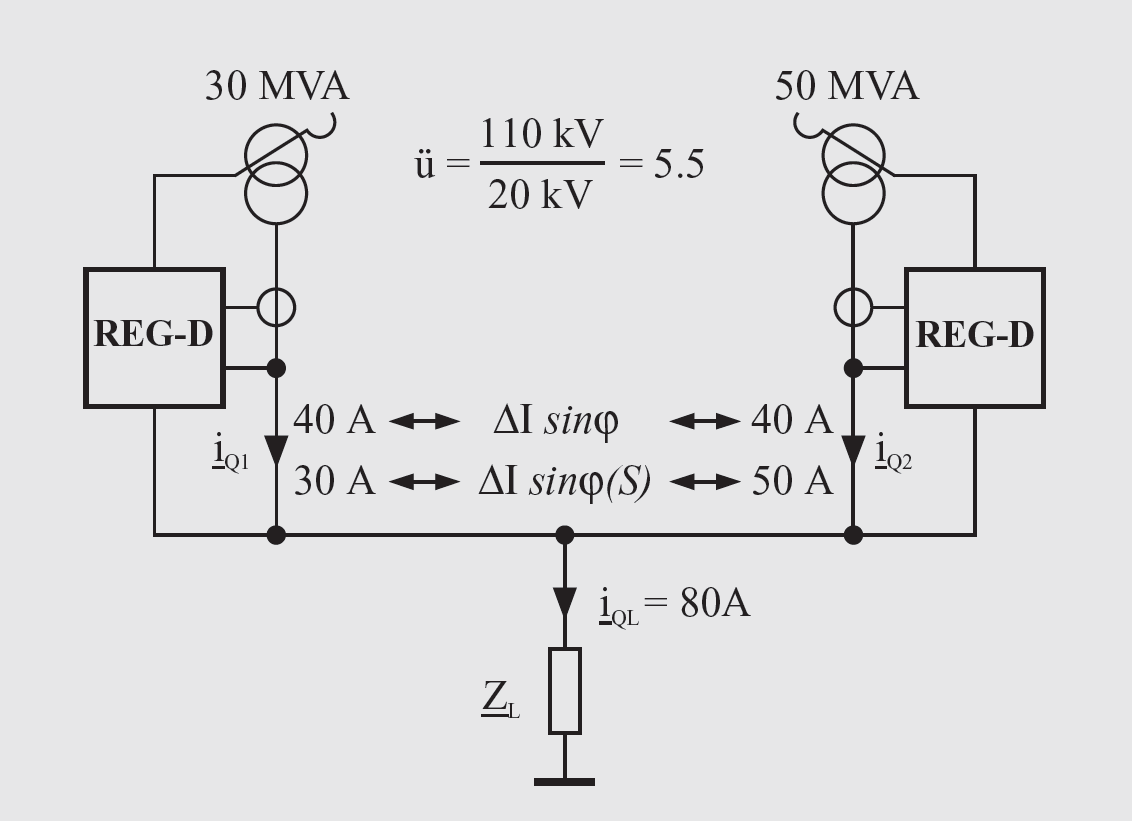
The ΔIsinϕ(S) method extends the ΔIsinϕ method by considering the rated powers of the transformers. This additional information allows the reactive current to be distributed according to the respective transformer ratings (see Figure 5):
icirQx = iQx - (iQ,tot · Sx/Stot) (9)

where:
Sx: rated power of transformer No. x
Stot: total rated power of all transformers
Δcosϕ Method
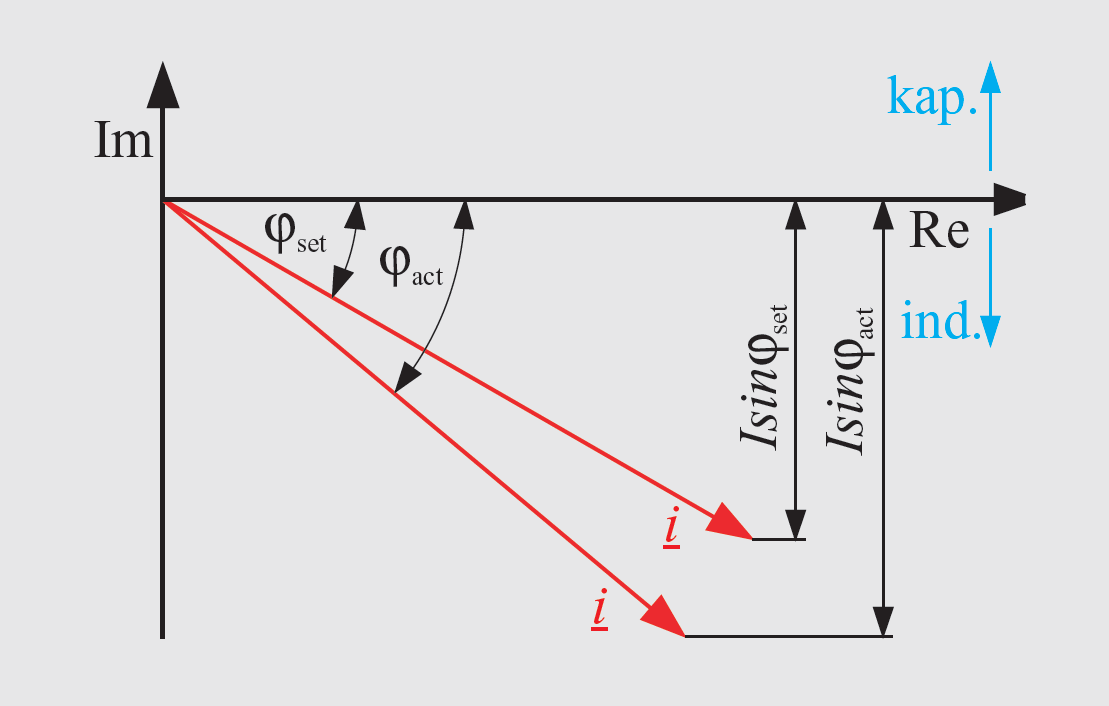
The Δcosϕ method has a special role among the parallel control methods. If several transformers feed a widely meshed network, the regulators may be unable to communicate via E-LAN. They can then neither exchange reactive current values nor calculate the circulating reactive current from these values. The operator first specifies the network power factor cosϕ as the setpoint. From the busbar voltage and transformer current, the regulator calculates the reactive current that would occur if the transformer cosϕ matched the network cosϕ. If the actual reactive current is higher, the regulator moves the transformer to a lower tap. If it is lower, the regulator moves it to a higher tap. The circulating reactive current is calculated as follows (see Figure 6):
icirQx = iTxsinϕact - iTxsinϕset (10)
Integration Into Voltage Control
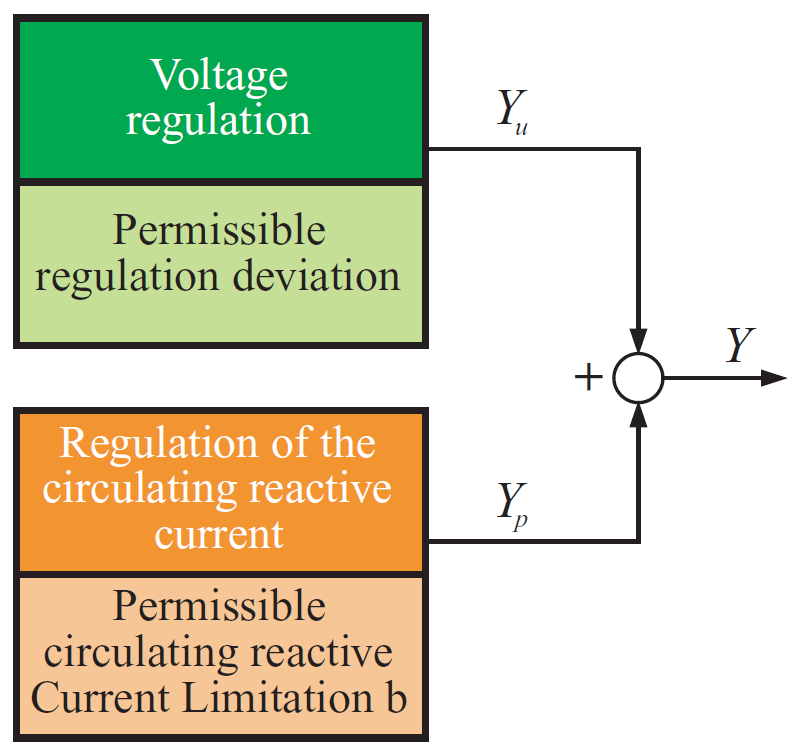
Voltage control alone is not sufficient for transformers in parallel. The circulating reactive current control therefore overlays the voltage control and counteracts unwanted circulating reactive currents (Figure 7). The control variables YU and YP are:
YU = (Uact – Uset) / ΔUperm (11)
YP = IcirQx / IcirQperm (12)

where:
Uact: actual RMS voltage
Uset: RMS voltage setpoint
ΔUperm: permissible control deviation
IcirQperm: permissible circulating reactive current
Deriving Tap Commands From the Control Variables
The resulting control variable Y is:
Y = YU + YP (13)
Equation (13) determines the tap commands. At Y > +1.0, the regulator issues LOWER; at Y < -1.0, it issues RAISE. The regulator controls voltage and circulating reactive current independently within their permissible deviations. If minimising the circulating reactive current would change the voltage beyond its permissible range, all transformers in parallel correct this deviation together. This prevents a permanent voltage control deviation.
Limiting the Influence of the Δcosϕ Method
The Δcosϕ method also has a special effect on voltage control. If the network cosϕ differs from the configured setpoint, it influences the voltage control. The remaining control deviation ΔU depends on the phase angles ϕset and ϕnet, the apparent current I, the permissible control deviation ΔUperm and the permissible circulating reactive current IcirQperm:
ΔU = ΔUperm · (sinϕset – sinϕnet) · I / IcirQperm (14)
Equation (16) shows how to limit this influence. In Figure 7, the parameter b defines the maximum permitted magnitude of YP.
|YP| < b (15)
This limits the remaining control deviation ΔU to:
ΔU = b · ΔUperm (16)
With strongly fluctuating loads and corresponding changes in the network cosϕ, a self-learning method can adjust the cosϕ setpoint. This avoids permanent voltage deviations and impermissibly high circulating reactive currents.
Safety Measures During Communication Failures
With all methods except Δcosϕ, the regulators involved in the parallel connection exchange the required data via E-LAN. Reliable control must continue if the E-LAN connection fails. Because Δcosϕ operates without a bus connection, it serves as an emergency programme. REG-D® includes this emergency programme as standard.
During normal operation with ΔIsinϕ or ΔIsinϕ(S), the regulator continuously measures the network cosϕ. After a bus failure, it uses the last measured value as the cosϕ setpoint and starts the Δcosϕ method. Once communication is restored, REG-D® returns to the previously active parallel control method.
If the bus connection fails during master-slave or master-follower operation, the slave automatically returns to individual regulator operation and issues an error message.
Simulating Parallel Operation With REGSim
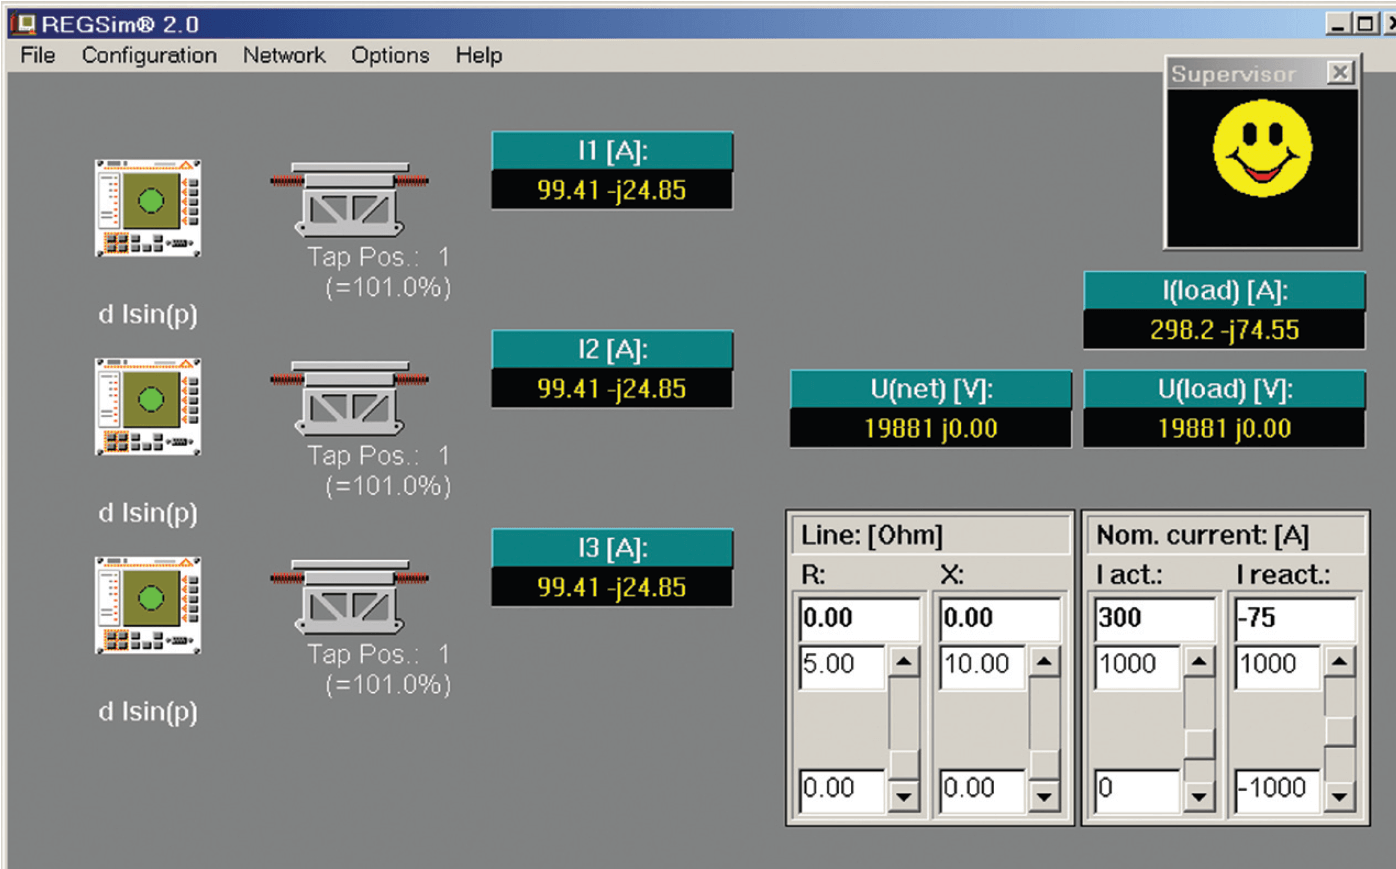
Figure 8 provides an initial theoretical indication of which parallel control method suits a particular system. REGSim (Figure 9) can simulate these methods in any operating configuration of transformers, network and loads. It uses the same control algorithms that are implemented in the regulator. Users can configure parameters such as rated voltage and transformer impedance.
REGSim therefore represents the REGSys® voltage regulation system in a specific system situation. Without intervening in the real system, users can examine how the control responds to extreme conditions such as load steps or earth faults. They can also estimate voltage stability and the number of tap operations in advance. The software is also suitable for training.
Automatic Parallel Operation
The ParaGramer (Figure 10) supports the automatic preparation of parallel connections and visualises switching states online. It shows the participating transformers, including circuit-breakers, disconnectors, bus couplers and bus sectionalising points, in a single-line diagram. Each regulator receives a complete busbar image through binary inputs. From the switching states, the system automatically recognises which transformers feed the same busbar in parallel. It treats busbars connected through bus couplers as one busbar.
In Figure 10, transformers T1 and T3 operate on busbar a, while transformer T2 feeds busbar b. ParaGramer can also represent high-voltage busbar configurations. It therefore supports the reliable implementation of a wide range of parallel connections with little effort.
FAQ - Frequently Asked Questions About Transformer Parallel Operation
Why does parallel operation of transformers require special control?
Different open-circuit voltages can cause substantial circulating currents because transformer impedances are low. A tap change at one transformer also affects the common busbar voltage only partly.
What is circulating reactive current in transformers?
Circulating reactive current results from differences between the open-circuit voltages of transformers in parallel. Because transformer impedances are predominantly inductive, these circulating currents are described as reactive currents.
When are master-slave and master-follower methods suitable?
Both methods are particularly suitable for identical transformers. With different rated powers, equal tap positions must produce equal transformation ratios. The relative short-circuit voltages must not differ by more than 10%.
What is the difference between ΔIsinϕ and ΔIsinϕ(S)?
ΔI sin ϕ distributes the target reactive current equally among the participating transformers. ΔI sin ϕ(S) also considers rated power and distributes the reactive current in proportion to the transformer ratings.
When is the Δcosϕ method suitable?
The Δcosϕ method is suitable when regulators in a widely meshed network cannot communicate through E-LAN. In REG-D®, it also serves as an emergency programme if the bus connection fails during ΔIsinϕ or ΔIsinϕ(S) operation.
What happens if the E-LAN connection fails?
During ΔIsinϕ or ΔIsinϕ(S) operation, the regulator uses the last measured network cosϕ as the setpoint and starts Δcosϕ. During master-slave or master-follower operation, the slave returns to individual control and issues an error message.
How does REGSim support the selection of a parallel control method?
REGSim simulates transformers, the network and loads with the control algorithms implemented in the regulator. Users can examine operating configurations, extreme conditions, voltage stability and the expected number of tap operations in advance.